Engineer.
Maker.
Builder.
amithnal
Amithnal
Herath
Mechatronics engineering graduate working across robotics, automation, embedded systems, and creative media.
Let’s connectTechnical Work
Robots, vision systems and machines built for factories, labs and clients. Pick a project and play with it: every one below is live.
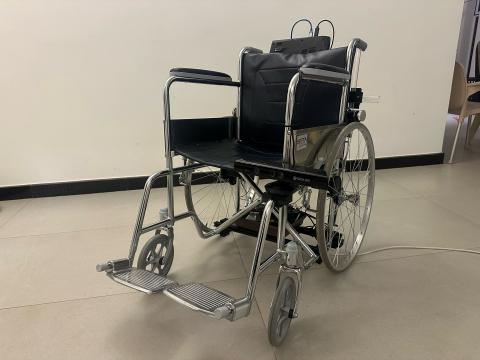
SMARTNAV wheelchair
A wheelchair you steer with your eyes or your face, or let it drive itself. EOG, an IR face tracker, depth and LiDAR all run as ROS 2 nodes on a Jetson Nano.
- Inputs
- EOG · IR face · depth · LiDAR
- Compute
- Jetson Nano
Delta robot vision
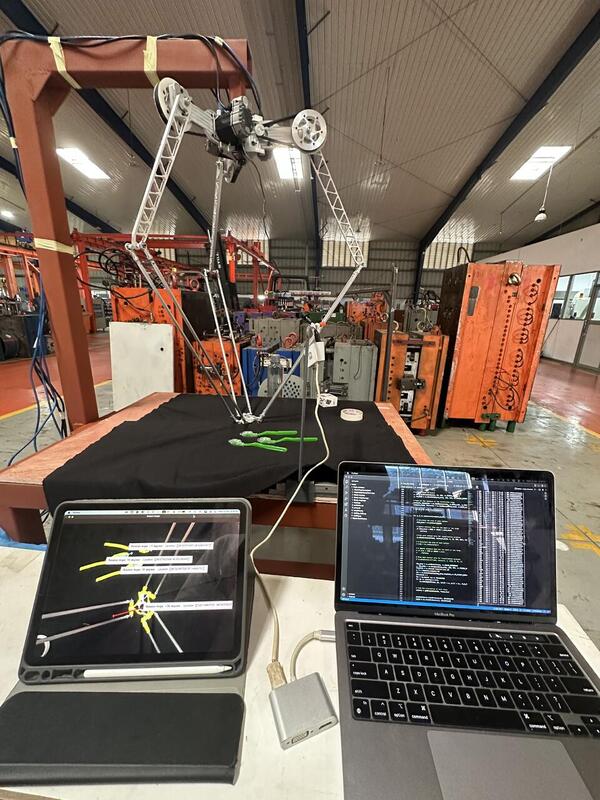
A camera over a moving conveyor gives a delta robot X, Y and angle for every toothbrush. PCA finds the axis; a head check fixes the 180° flip. Rotate the brush below.
- Output
- X, Y, θ per item
- Stack
- Python, OpenCV
- PCA axis
- 35°
- Sent to robot
- 35°
Street vehicle detection
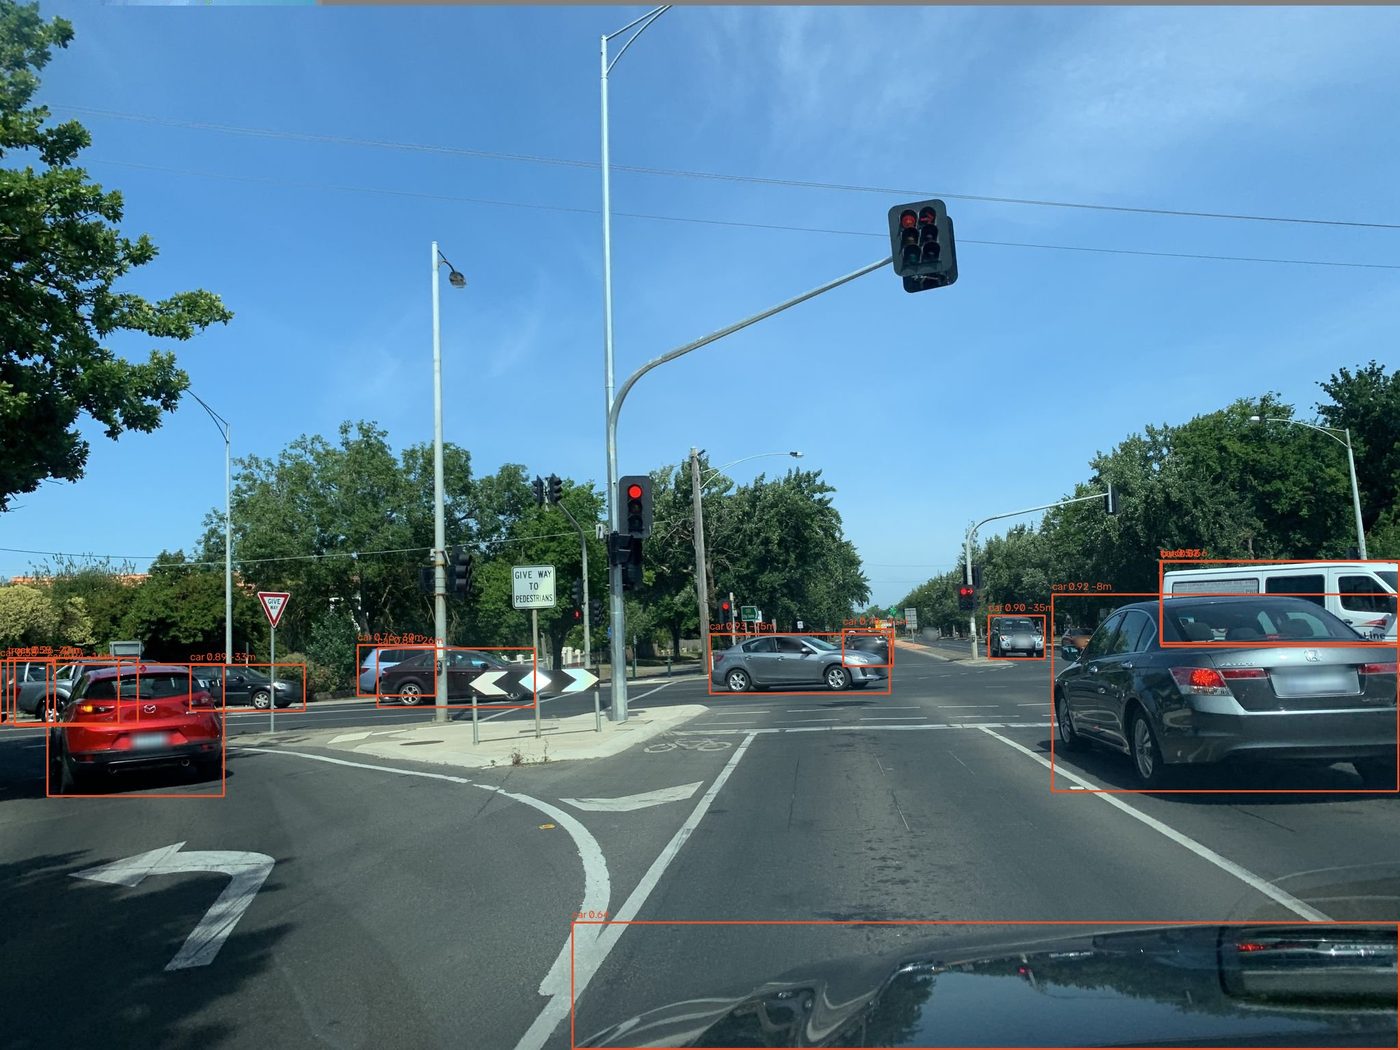
YOLO11 over a whole town's licensed street imagery, merged and clustered into one record per vehicle for a person to review.
- Images
- 1,844
- Detections
- 6,917
- Vehicles
- 2,460
Tap a step
Detections by class
Hover a bar.
H-bot XY table
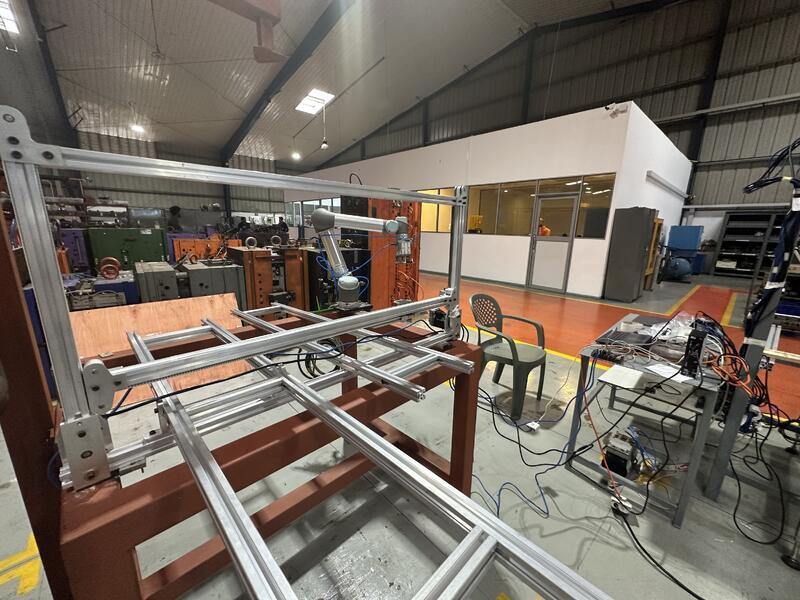
ClearCore firmware for a large H-bot positioning table. Both motors share one belt, so every move mixes the two. Click anywhere on the table below.
- Controller
- Teknic ClearCore
- Move
- X, Y, feed, accel
- Target
- X 0 · Y 0
- Motor A
- 0
- Motor B
- 0
Both motors turning the same way slides the beam along Y. Opposite ways moves the carriage along X. Anything else is a mix.
Lane detection at night
Seven stages from a raw night frame to two fitted lane lines, with thresholds the frame chooses itself. Step through it.
- Scale
- 416.7 px/m
- Camera
- Zed2i
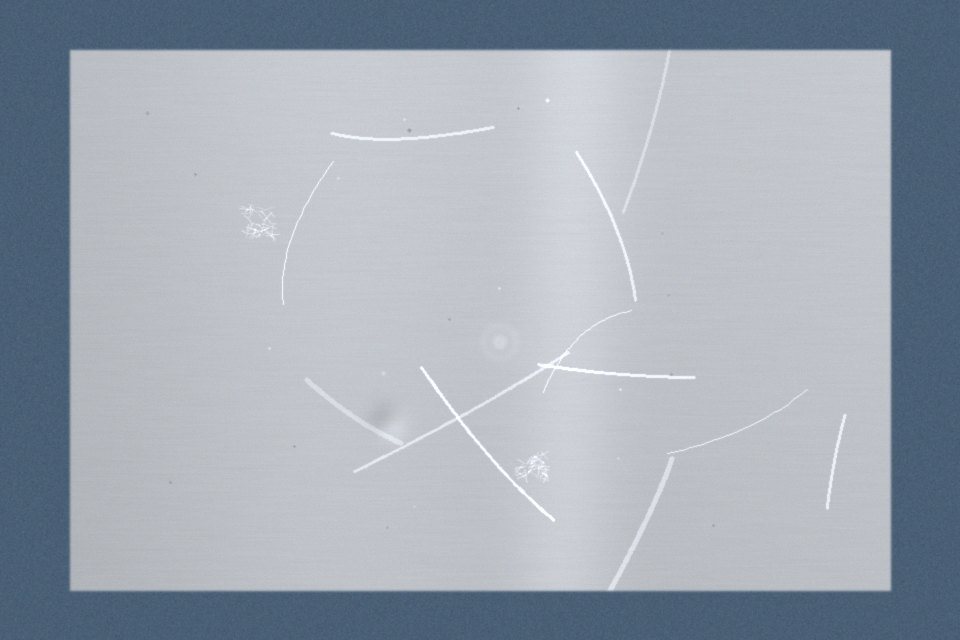
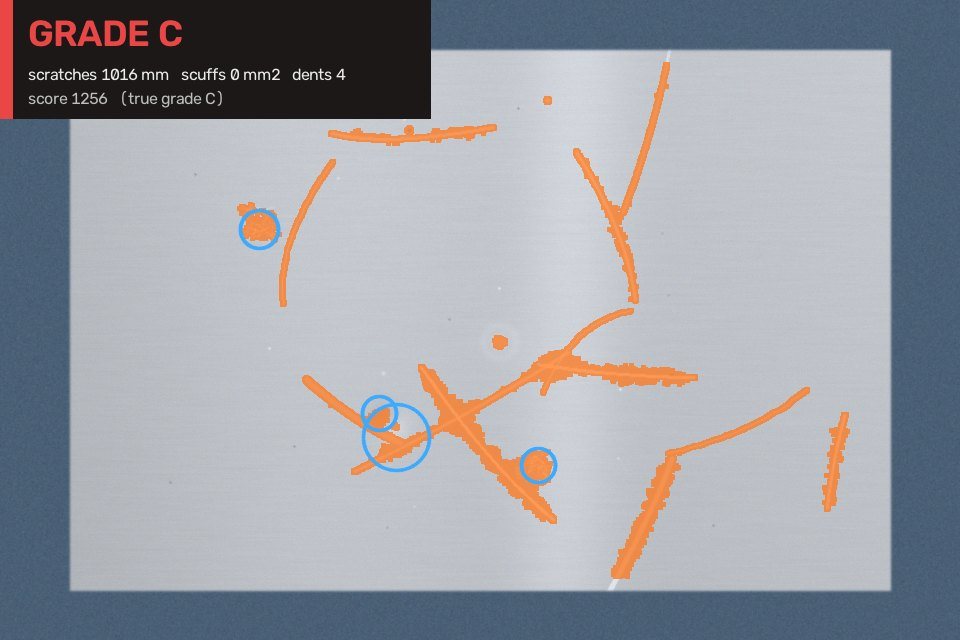
Cosmetic grading
Scratches and dents measured in millimetres and turned into grade A, B or C, with no training data. Drag to compare the photo with what it found.
- Held-out accuracy
- 93.3%
- Test lids
- 180
More builds
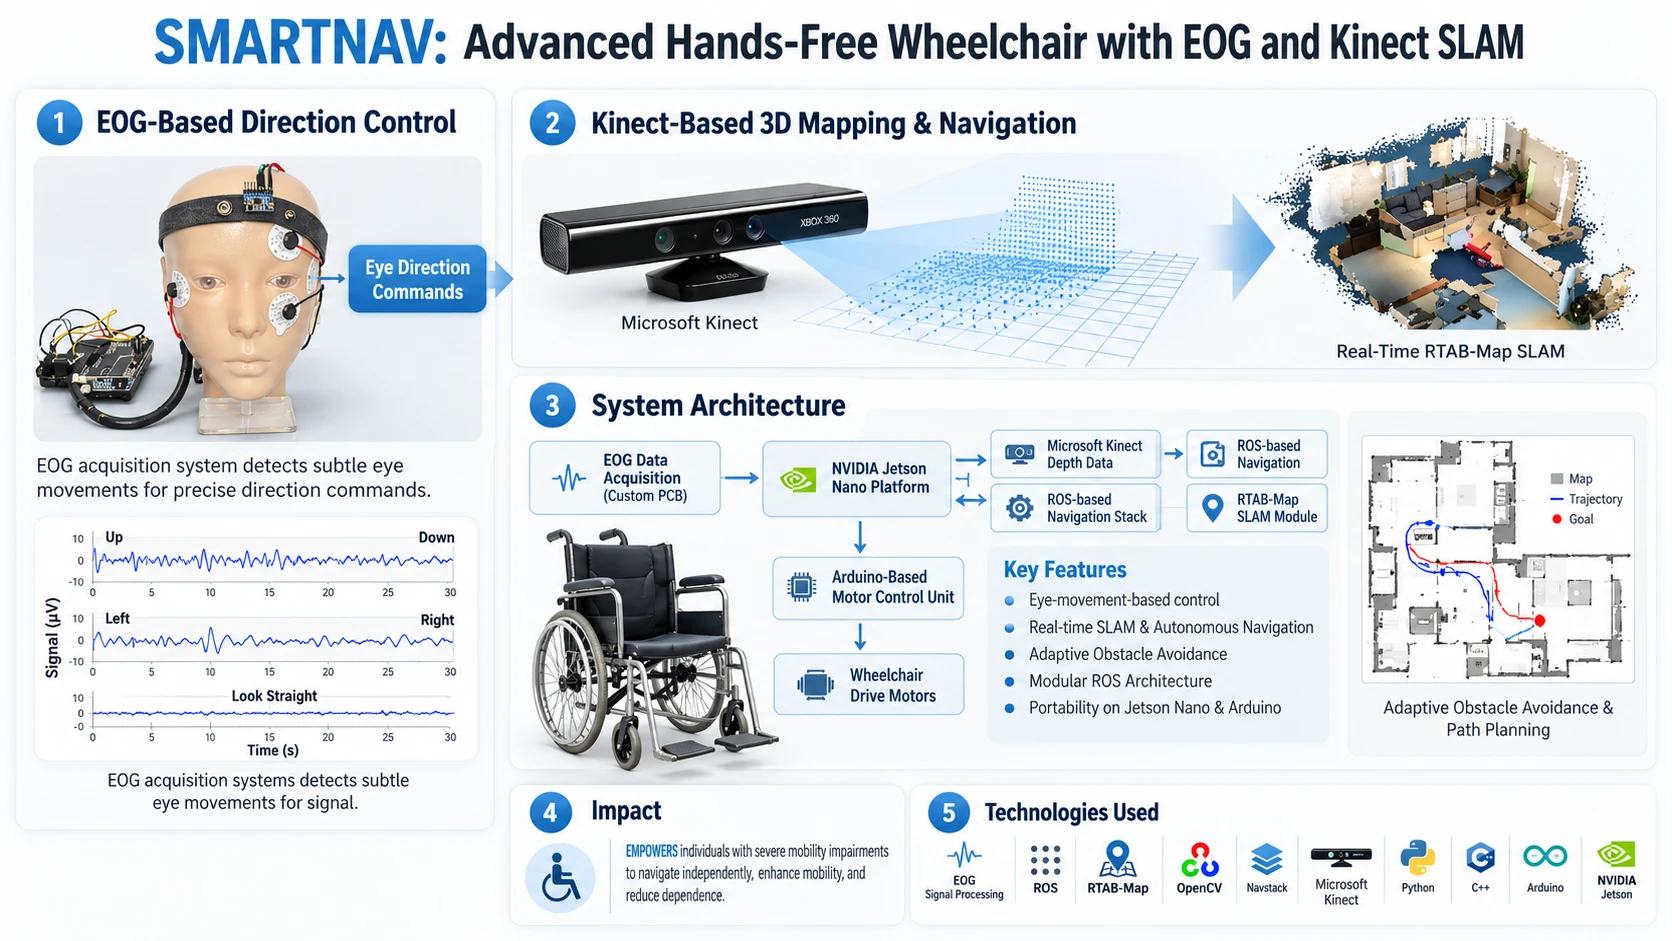
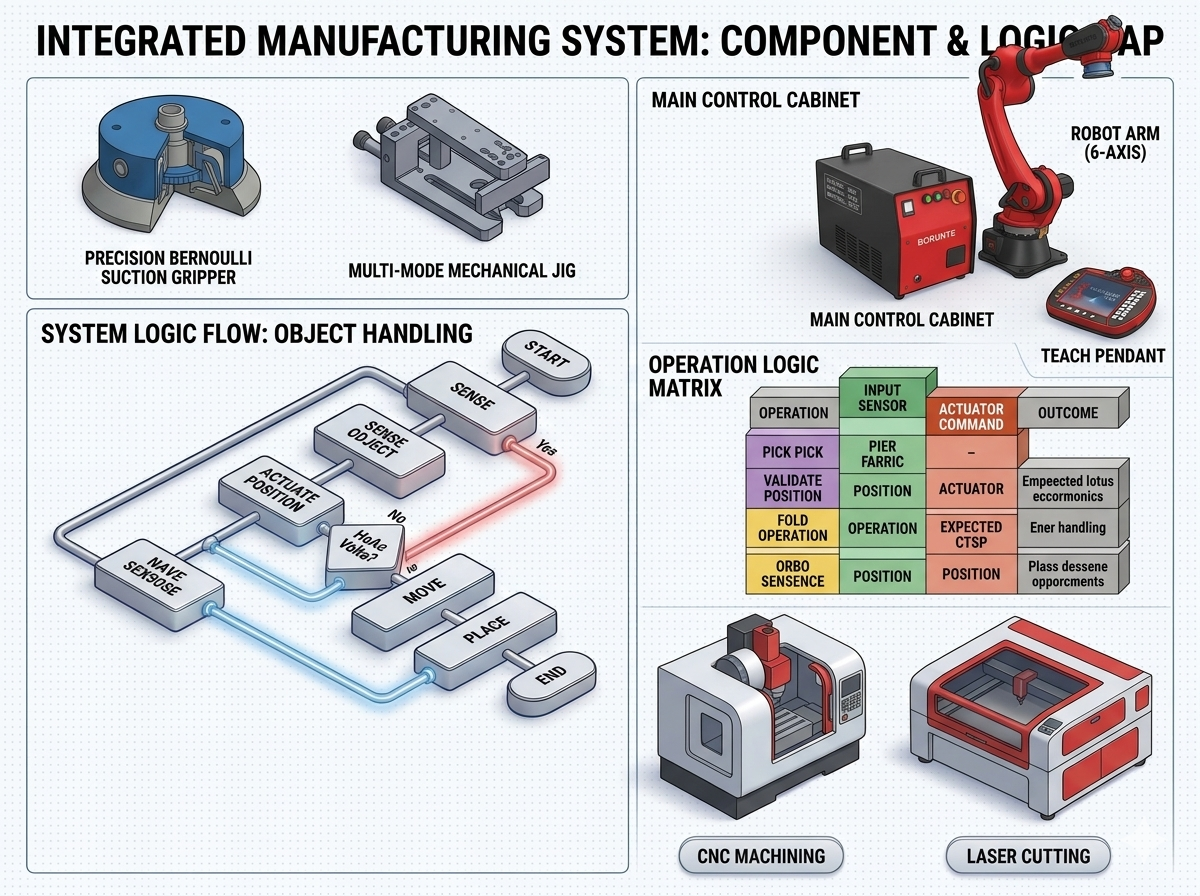
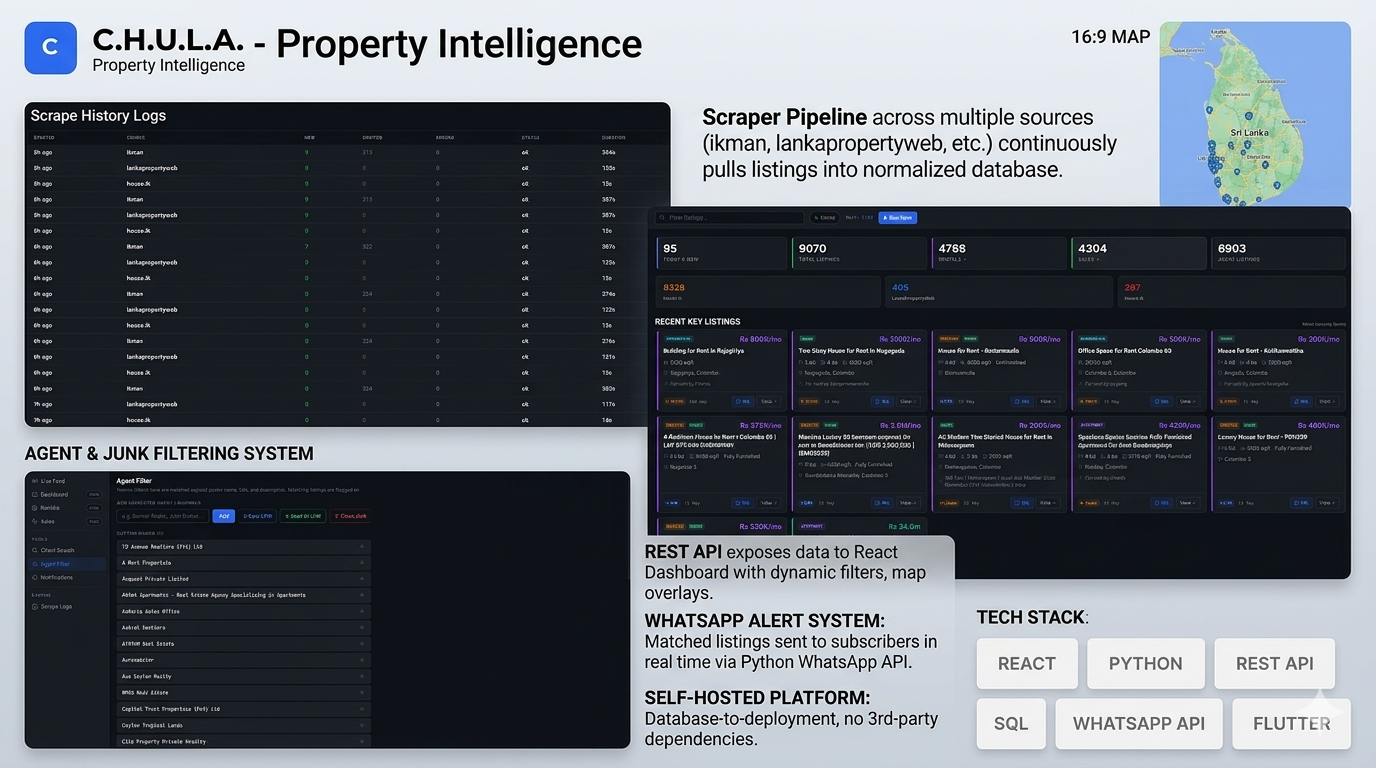
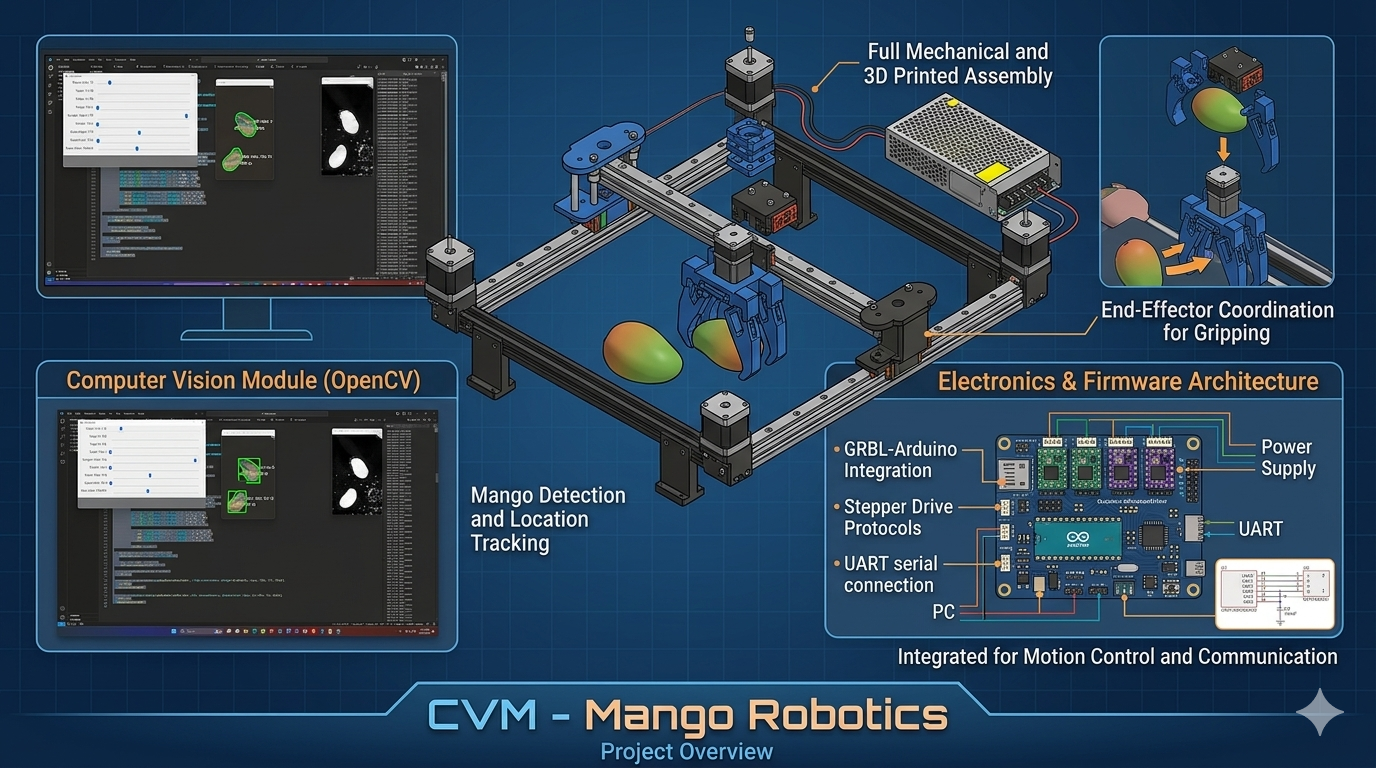
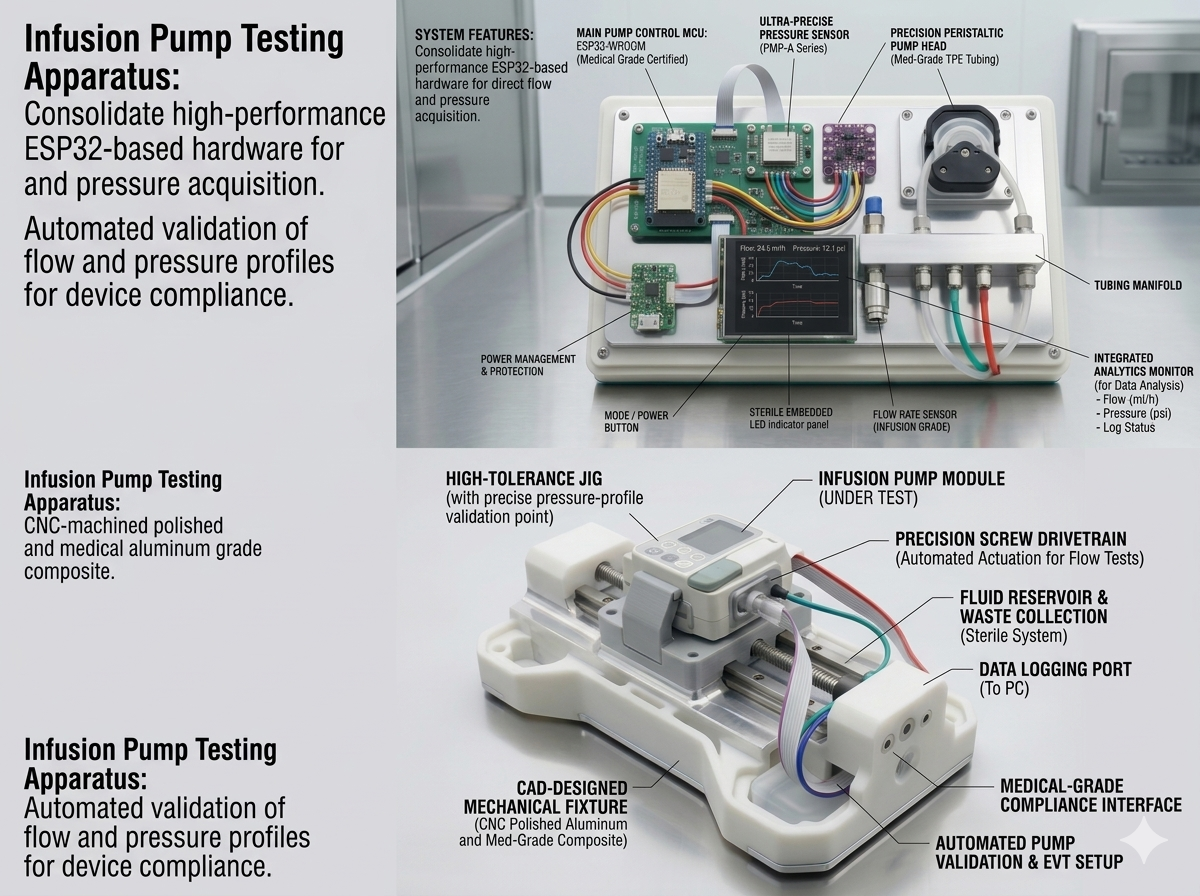
Twelve more builds on the technical page, from SLAM and robot arms to PLCs, FPGAs and IoT, each with its own interactive breakdown.
View all projectsLearning systems, on real hardware.
Master's in Robotics at Monash: computer vision, state estimation, learning-based navigation and reinforcement learning. My models run on robots, camera rigs and production lines.
Creative Work
Brand, Lens, Motion & Screen